Free offline waypoint mission planner for the DJI Mavic 3 ProPlan the flight.Own the data.
The mission planner DJI Fly never shipped. Map an area for photogrammetry, orbit a tower for a 3D model, scan a façade or sketch a cinematic camera move – and get a flight-ready waypoint KMZ with overlap, GSD, battery use and camera settings solved before the drone leaves the ground. Then upload it to your DJI RC Pro over USB in one click. Play with the planner right on this page.
Why I built this
DJI Fly flies a mission – it doesn't design one. Every planner I tried lived in the cloud, wanted a subscription, locked the interesting parts behind a tier, or simply couldn't plan the jobs I actually do.
So I wanted something different: a planner that is offline, local and fully customizable – one that does more than any other solution on the market. Something I could trust in a field with no signal, with every site and every photo staying on my own machine, and deep enough for the odd, demanding jobs: a quarry, a façade, a monument, a cinematic dolly shot.
Mavic Mapper is the result. And now it's available for anyone to use – absolutely free of charge, without restrictions.
Offline & local
One native program. Double-click, the browser opens, you plan. Only optional lookups (maps, elevation, OSM, weather) touch the internet.
Fully customizable
Every limit, slider range, preset and default is yours to change – even the accent colour.
More than the rest
Grid, crosshatch, oblique, orbit, façade, cinematic video, chaining, terrain following, wind, gap analysis…
Free, no strings
No licence keys, no trial timer, no feature walls. Download it, use it, share it.
From download to first flight in 5 steps
No installer, no account, no setup wizard. Click through the steps – they play automatically.
Know your cockpit
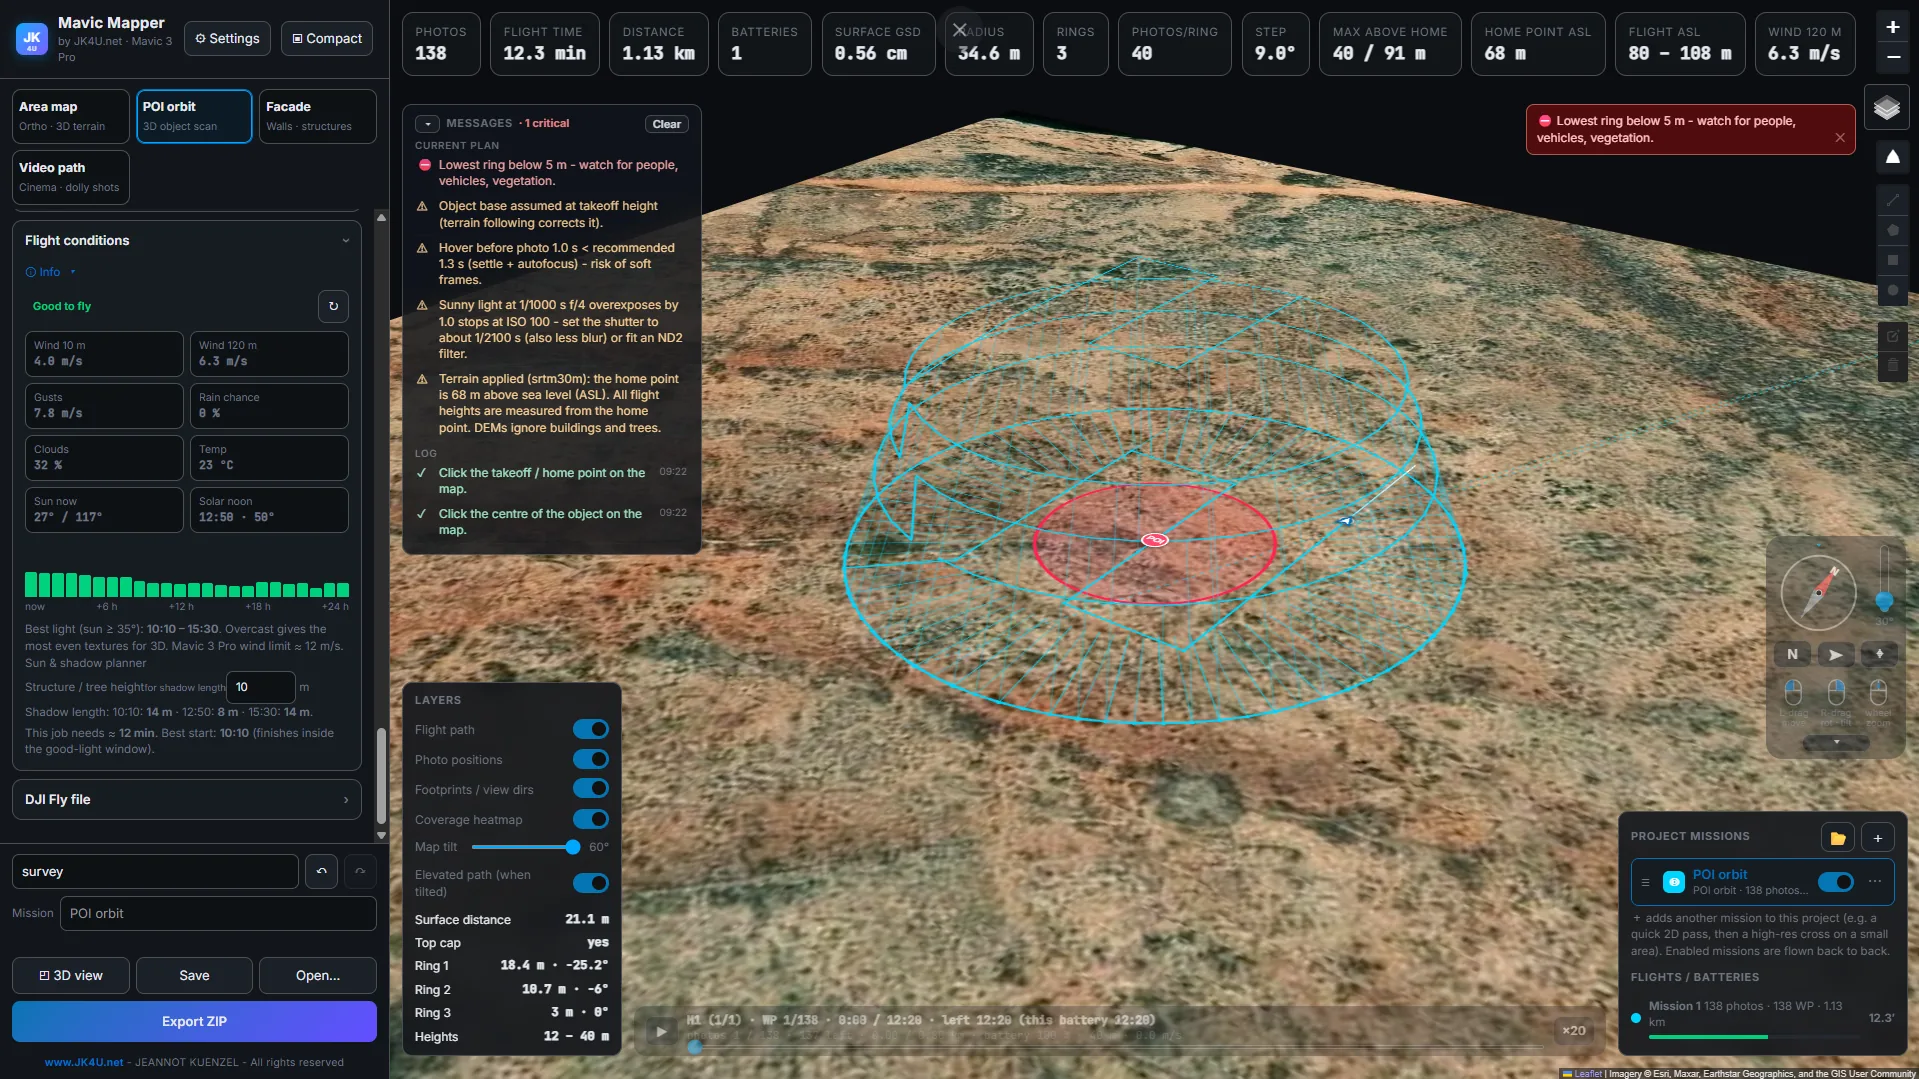
Tap the pulsing numbers on a real Mavic Mapper screen to see what each area does.
Plan a mission right here
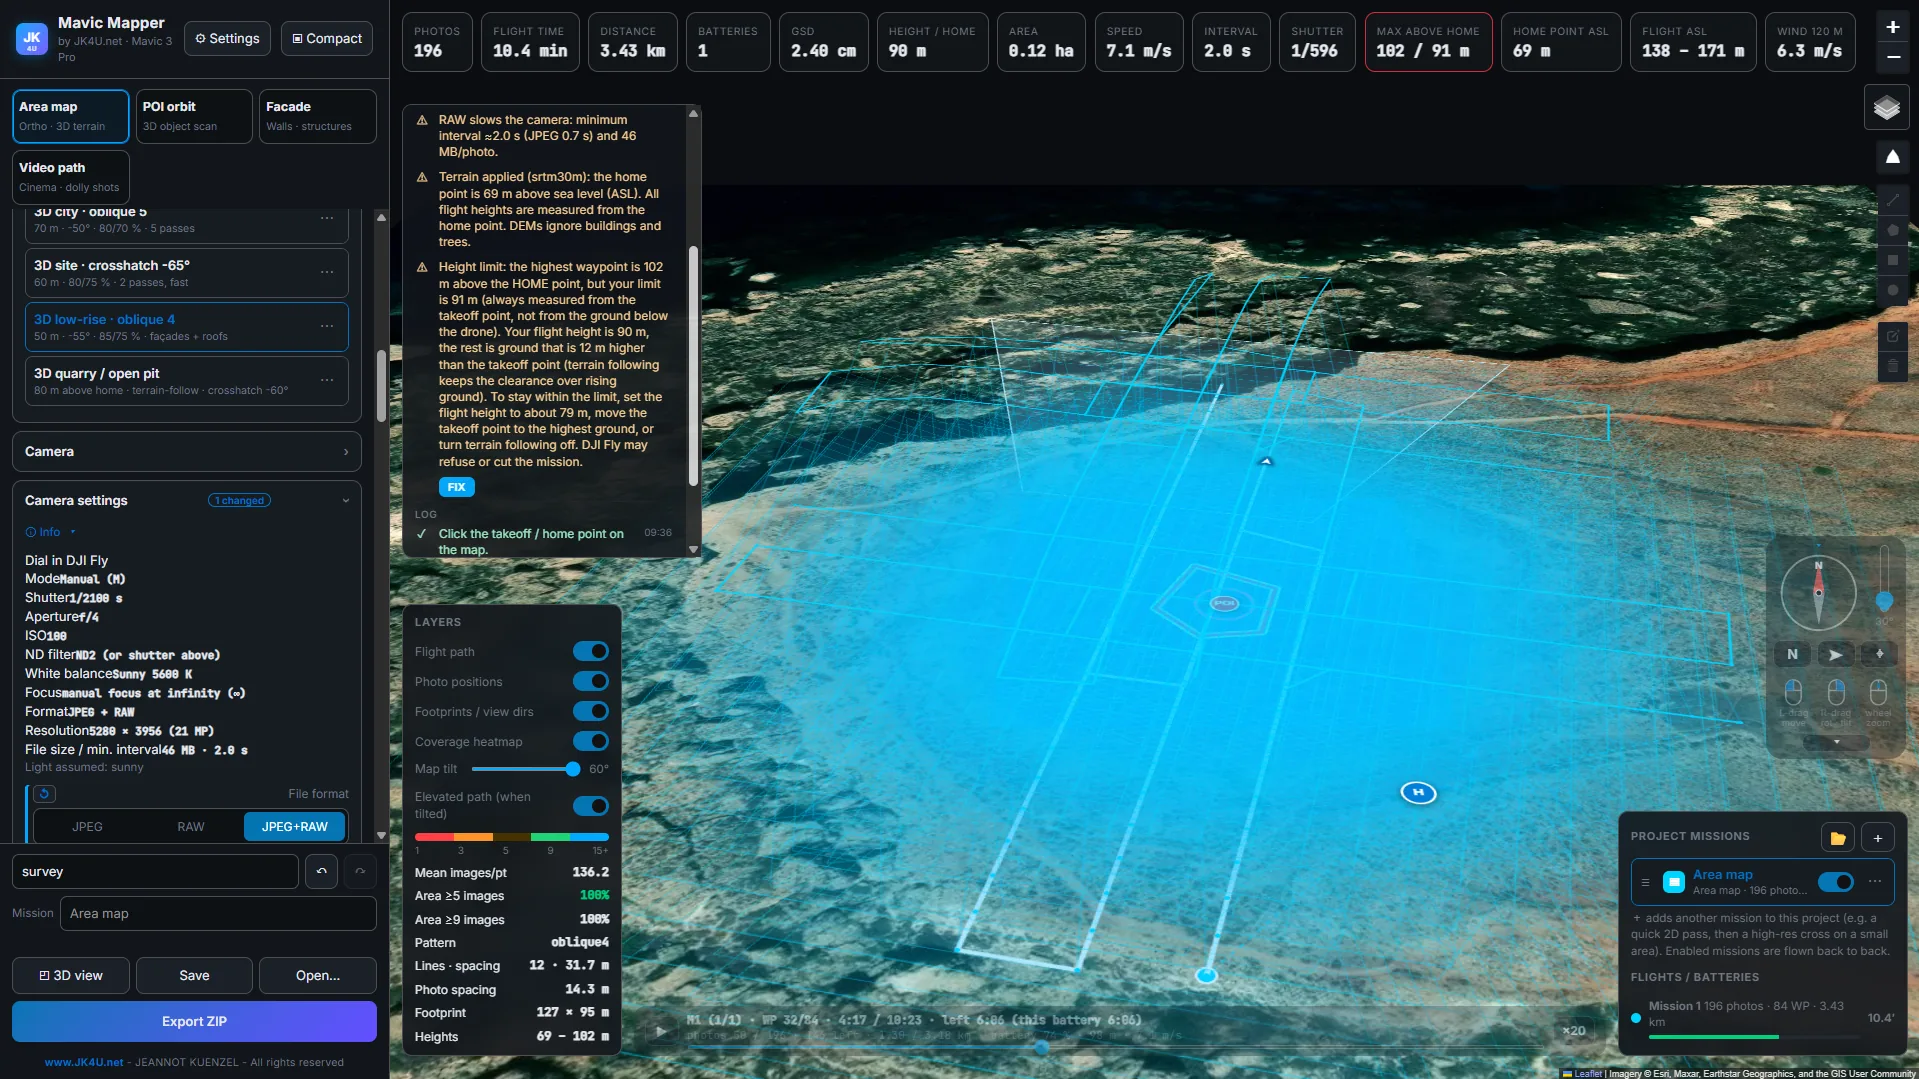
A live replica of the planner's maths – the same camera data, footprints, overlap, blur and battery logic. Drag the sliders, rotate the 3D view with your finger or mouse, press play and watch the drone fly it.
Six jobs. Every function.
Real-world missions built from the app's own presets. Hit “Load in Lab” to fly them in the simulator above – then recreate them in Mavic Mapper in minutes.
44 presets. One tap.
Mavic Mapper ships with built-in shooting setups for mapping, inspection, 3D scanning, façades and cinema. Tap one to apply it – tweak – save your own as .mmpreset.json.
One drone, three cameras to plan for
Each Mavic 3 Pro camera has its own sensor geometry, aperture, minimum photo interval and file size. Move the altitude slider and see how footprint and GSD change per lens.
Never guess your camera settings
Waypoint files cannot carry exposure – so the planner tells you exactly what to dial in DJI Fly: shutter, ISO, ND filter, white balance, focus. Try it for photos and video.
The planner talks to you
The most important rule in the app: all heights are above your home (takeoff) point. Place the ⌂ marker where you really launch – then the planner checks everything else.
⌂ Home point = height reference
DJI expects waypoint heights relative to the takeoff point. Mavic Mapper does the same – and warns when the highest waypoint exceeds your height limit (default 120 m) measured from the home point, not from the ground below.
⛰ Terrain following
Switch it on and waypoint heights are corrected against real elevation data (SRTM, EU-DEM, ASTER or Mapzen), so ground clearance – and GSD – stay constant over hills. Try the toggle in the Area-map tab of the Mission Lab.
🧯 One-click FIX
Many warnings come with a FIX button that solves the problem by itself – and drops out again when no longer needed. Try it below.
Fly smart, then verify
Complex sites need different treatment in different places. Let OpenStreetMap find the buildings and trees – then close the loop with a post-flight gap analysis.
- Find asks OpenStreetMap for buildings and tree areas inside your outline and clusters them into zones.
- Per-zone tuning: own overlap, pattern (denser crosshatch / oblique for buildings), altitude multiplier and gimbal.
- Zone lines merge into the main plan and share the batteries.
- Zones only turns them into a small patch mission for re-flying.
Find the holes before the model does
Select the flown JPGs – their DJI position, yaw and pitch are read right in the browser. Red = fewer than N images.
- Analyze the photos against the plan.
- Create re-fly mission: gaps become ready-to-fly, zones-only patch missions.
- Back to full plan reverts at any time.
Big jobs, many batteries, one project
Combine several missions into a project – the planner splits and balances them over batteries, and can resume from any waypoint after an interruption.
The drone flies straight home → waypoint at takeoff safety height – check that leg for the obstacle that stopped you.
Plug in. Click Upload. Your RC Pro just levelled up.
DJI Fly flies waypoint missions but gives you no way to bring your own in. Mavic Mapper closes that gap: it talks to your DJI RC Pro, RC 2 or Android phone over USB-C using ADB and drops finished missions straight into DJI Fly – bringing an RC Plus 2–style mission workflow to the controller you already own. No cloud, no copy-paste, no folder hunting.
- One click per battery. Mission 1 → slot 1, Mission 2 → slot 2 … Mavic Mapper writes each KMZ into the matching DJI Fly mission folder.
- Backs up first. Every replaced mission is saved to
rc_backups/and can be restored with one button. - Copies your drone IDs. It reads
droneEnumValueand the payload code from the dummy mission, so DJI Fly accepts the file for your aircraft. - Verifies the transfer. File size is checked after the push; failures are reported per mission.
- Restarts DJI Fly for you. Force-stop and relaunch, so the new mission shows up immediately.
- Installs ADB by itself. Google's platform-tools are downloaded automatically – nothing to set up by hand.
How it works – six steps, once
Create dummy missions
In DJI Fly, save one simple 2-point waypoint mission per battery. They are placeholders: each one creates a mission slot on the controller.
Enable USB debugging
On the RC: Settings → About → tap the build number 7× to unlock Developer options, then switch on USB debugging. Menu names vary a little by controller and Android version.
Connect with USB-C
Plug the RC into your computer, unlock it and accept the “Allow USB debugging?” prompt. Tick Always allow for this computer.
Install ADB & detect
Press Install ADB tools (one time), then Detect RC. Your controller and every saved mission slot appear in a list – newest first.
Assign mission → slot
Auto-assign pairs the missions with your dummy slots – or choose manually. Each slot shows its date, size and waypoint count so you can't pick the wrong one.
Upload & fly
Press Upload. DJI Fly restarts, you open the mission, set camera settings from the summary and launch. Next battery, next mission.
Three ways to reach your controller
🔌 ADB over USB
Works with DJI RC Pro, RC 2 and Android phones running DJI Fly – including newer Android versions that block normal file access to Android/data.
- Auto-downloads Google platform-tools
- Detects the right DJI Fly package
- Backup · upload · verify · restart
🪟 Windows file transfer (MTP)
No ADB needed: Windows sees the controller as a portable device and Mavic Mapper writes through it.
- Windows only
- Same slot list and backups
- No automatic app restart – reopen DJI Fly yourself
📡 Directly on the RC
Run the planner on the controller itself: with the on-RC helper it talks to the RC's own ADB service – no computer in the field.
- Set up once from the PC installer
- Plan, upload and fly from the same device
- Falls back to direct file access where Android allows it
| Per mission | Doing it by hand | Mavic Mapper USB upload |
|---|---|---|
| Find the right folder | Browse GUID folders, compare dates | Slot list with date, size, waypoints |
| Rename the KMZ | Must match the dummy file name exactly | Automatic |
| Drone ID in the file | Wrong ID = DJI Fly rejects it | Copied from the dummy mission |
| Backup of the old file | You remember to copy it | Always, with 1-click restore |
| 5 batteries | 5 × the whole routine | One Upload press |
Prefer to do it by hand, or don't have a cable at the field? See the manual step-by-step guide below. Always keep the aircraft in visual line of sight and test every new mission slowly.
How to get a waypoint mission into DJI Fly by hand
No ADB, no problem. DJI Fly can't import a KMZ directly, but there is a well-known trick: replace the file of a placeholder mission. The steps are the same for any KMZ in DJI's WPML format – including the ones Mavic Mapper exports.
Export your mission
In Mavic Mapper press Export. Unzip the result: you get one mission_01.kmz per battery. The file must be in WPML format (DJI's standard) – a plain Google Earth KML will not work.
Create a placeholder mission in DJI Fly
On the controller (or phone), open DJI Fly → Waypoint → add two points anywhere, save it and give it a name. Create one placeholder per KMZ you want to import.
Open the controller's file system
Connect the RC to your computer with USB-C (or use a file manager on the device) and browse to:
Android/data/dji.go.v5/files/waypoint/Each saved mission lives in its own folder named with a long GUID. On newer Android versions the Android/data folder is hidden from apps and some file managers – use a PC, a microSD workaround or the ADB method above.
Find your placeholder's folder
Sort the folders by modified date: the most recently created one is your placeholder. Inside is a single .kmz named exactly like the folder (the GUID).
Swap the file
First copy the original somewhere safe (backup). Then rename your own KMZ to exactly the same file name as the placeholder's KMZ, delete the placeholder file and copy yours into the folder. DJI Fly only updates missions by overwriting that exact file name.
Reopen the mission in DJI Fly
Force-close DJI Fly (swipe it away) and open it again. Open the placeholder mission: the waypoint editor loads your route and the thumbnail updates. Check heights, speed, gimbal and actions – and set the RTH height.
Set camera settings, then fly
Waypoint files cannot carry exposure. Open Mavic Mapper's summary.txt and dial in shutter, ISO, ND filter, white balance and focus by hand. Fly within visual line of sight, then repeat for the next battery.
Background & further reading: Litchi Utilities – DJI Fly waypoint KMZ import · MavicPilots – where waypoints are stored · MavicPilots – back up, export & import · Dronelink – onboard waypoint missions to KMZ. Folder layout and menu names can change with DJI Fly updates.
What you get when you press Export
One ZIP: a DJI WPML KMZ per battery with photo, hover, gimbal, yaw and recording actions, a Google-Earth overview, a plain-text briefing and WebODM options. Below is a live preview built from your current Mission Lab settings.
One KMZ per battery
Automatic splitting with balanced flight times, plus a resume helper.
Template matching
Read a KMZ created by DJI Fly so the output matches your aircraft and payload exactly.
Google Earth overview
Fly the mission virtually before you leave the office.
Your planner, your rules
Mavic Mapper adapts to your screen, your remote controller and your habits. Try the accent colour – this whole page re-themes.
Desktop or compact layout
Large-screen cockpit, or a compact touch layout that works beside the RC clock and battery bar (top-bar clearance is adjustable).
Base maps
Google hybrid, Google satellite, Esri satellite or dark streets.
Slider ranges
Set your own min / max for any slider.
My defaults
Make the current settings your starting point.
100 undo steps
Undo / redo with adjustable history, plus autosave.
Plain local files
Projects and presets are JSON files in a folder you choose.
Pilot's cheat sheet
Overlap & gimbal
| 2D ortho | 75 / 65 %+ · −90° |
| 3D reconstruction | 80 / 70 %+ · −50…−65° |
| Vegetation | 85 / 80 % |
| Façade | 80 / 70 % · 0° (perpendicular) |
Video speed vs. distance
| Close (10–20 m) | 1.5–3 m/s |
| Mid (30–60 m) | 3–6 m/s |
| Landscape | 8–12 m/s |
| Yaw / gimbal, slow move | ≤10–15 / 5–8 °/s |
Cinematic camera
| Frame rate | 24 / 25 / 30 fps |
| Shutter angle | 180° = 1/(2·fps) |
| Codec / res | H.265 · 5.1K / 4K |
| Test run | 50 % speed first |
The whole flight loop is coming
Beyond planning and USB upload, these tools are on their way to the native edition:
🧭 Fly assistant
A pre-flight checklist, one-tap mission preparation and a hold-to-start button.
- Prepare Mn opens the right mission in DJI Fly
- Record your own tap macros – open, start, pause, resume
🧪 ODM processing
Send the photos to NodeODM / OpenDroneMap and get results back.
- Orthophoto, DSM and 3D model, options tuned to the mission
- Quality presets: fast · balanced · high
📐 Results & measuring
Review results on the map and measure what changed.
- Distance, area and stockpile volume
- Change detection A → B: raised in red, lowered in blue
Your sites. Your data.
Your computer.
One native executable – no Python, no installer, no server, no account. Planning happens entirely on your machine; only optional lookups use the internet. The planning engine is compiled native code, verified against the reference planner on 56 plan scenarios, 56 export bundles and the terrain, zone, gap-analysis and import functions.
Everything Mavic Mapper can plan – the complete index
All 44 built-in presets, the six cinematic shot recipes and the step-by-step tutorials for the DJI Mavic 3 Pro waypoint planner, in one searchable list.
2D mapping
- Ortho · fast (area map) – 80 m · 80/70 % · ~2 cm/px · moving
- Ortho · high detail (area map) – 45 m · 85/75 % · stop & shoot
- Ortho · large area (area map) – 115 m · 75/65 % · max coverage per battery
- Ortho · medium tele 48 MP (area map) – 90 m · 80/70 % · long standoff, low perspective
- Ortho · vegetation / crops (area map) – 70 m · 85/80 % · low texture, wind-moved canopy
- Corridor · road / pipeline / river (area map) – 60 m · 80/60 % · narrow polygon
- Ortho · hilly terrain (area map) – 70 m above home · terrain-follow · 80/75 %
Inspection & volumes
- Construction progress (area map) – 60 m · 80/70 % · repeatable, same settings each visit
- Stockpile / volume (area map) – 50 m · crosshatch · 80/75 % · place GCPs
- Roof / solar survey (area map) – 35 m · 85/75 % · stop, RAW for glare recovery
3D mapping (oblique)
- 3D city · oblique 5 (area map) – 70 m · -50° · 80/70 % · 5 passes
- 3D site · crosshatch -65° (area map) – 60 m · 80/75 % · 2 passes, fast
- 3D low-rise · oblique 4 (area map) – 50 m · -55° · 85/75 % · façades + roofs
- 3D quarry / open pit (area map) – 80 m above home · terrain-follow · crosshatch -60°
Buildings
- House / small building (POI orbit) – 10 m high · auto rings · top cap
- Large building / hall (POI orbit) – 25 m high · 40 m wide · top cap · 85 % front
- Ruin / heritage site (POI orbit) – 12 m · RAW · dense rings, 85/75 %
Tall structures
- Tower / church / monument (POI orbit) – 40 m high · 12 m dia
- Mast / chimney / pylon (POI orbit) – 50 m high · 3 m dia · 12 m standoff
- Wind turbine tower (POI orbit) – 80 m high · 6 m dia · 20 m standoff
Objects
- Statue / sculpture (POI orbit) – 5 m high · 6 m standoff · 3 rings
- Vehicle / machinery (POI orbit) – 3 m high · 5 m dia · 3 rings · top cap
- Monument · tele 48 MP (POI orbit) – 12 m · 25 m standoff · long lens, no perspective
Façades & faces
- Building façade (façade) – 10 m standoff · 3-20 m
- High-rise façade (façade) – 20 m standoff · 5-80 m · -5° pitch
- Heritage façade · tele detail (façade) – 30 m · medium tele 48 MP · 85/75 %
- Cliff / quarry face (façade) – 25 m standoff · 5-60 m
- Dam / retaining wall (façade) – 15 m · 2-40 m · -10° pitch · crack detail
Property & architecture
- Property · slow glide (video) – 2 m/s · 5.1K/24 · max smoothing
- Property · push-in (video) – 1.5 m/s · 4K/24 · straight, locked heading
- Pedestal rise & reveal (video) – 2.5 m/s · 1.5 m/s climb · tilt-down reveal
- Dolly · Inspire-style (video) – 2.5 m/s · floating, soft starts
- Reveal · slow push-in (video) – 3.5 m/s · 4K/24
Landscape & travel
- Landscape · high glide (video) – 6 m/s · 5.1K/24 · wide, stable
- Ridge / cliff reveal (video) – 4 m/s · climb + tilt-down
- Coast / water run (video) – 7 m/s · 4K/30 · low pass
- Fly-by · medium (video) – 8 m/s · 4K/30
- Blue hour / low light (video) – 2.5 m/s · 4K/24 · 180° shutter, low speed
Action & slow-motion
- Tracking · follow (video) – 9 m/s · 4K/60 · fast yaw
- Fast chase (video) – 12 m/s · 4K/30
- Slow-mo fly-by (video) – 10 m/s · 4K/120 · 1/240 shutter
- Site progress video (video) – 5 m/s · 4K/30 · repeatable path
Long lens
- Tele compression pass · 166 mm (video) – 5 m/s · 4K/30 · ≥ 30 m standoff, slow yaw
- Medium tele lateral track · 70 mm (video) – 6 m/s · 4K/30 · parallel to subject
Shot recipes
Push-in (dolly in)
- Straight track toward the subject, slow. Camera locked on it.
- Look: POI. 3 points, height 30 → 14 m, 2 s hold at each end.
- Use: reveal detail, build tension. Subject grows, background compresses.
Pull-out (dolly out / reveal)
- Start close and low on the subject, retreat and rise.
- Look: POI. Height 10 → 40 m.
- Use: end shot, reveal the setting around the subject.
Truck (lateral slide)
- Straight sideways track past the subject, camera fixed to the subject direction.
- Look: fixed heading, gimbal −8°, constant 15 m. Standoff 30 m.
- Use: parallax, foreground passing the subject. Keep speed ≤ 4 m/s.
Crane / pedestal up
- Near-vertical rise with slight forward drift; gimbal tilts down while rising.
- Look: fixed heading, gimbal −3° → −35°, height 4 → 50 m.
- Use: reveal a landscape behind a foreground object.
Orbit arc around subject
- 180° arc at constant radius and 25 m height; subject stays centred.
- Look: POI. Radius = distance / 2 (min 25 m).
- Use: hero shot. Slow speed (2–3 m/s) for a floating look.
Fly-over / tracking path
- Gentle S-curve path, camera looks along the direction of travel.
- Look: along path, gimbal −15°, height 35 → 30 m.
- Use: follow a road / coast / river. Medium speed (8 m/s).
Tutorials
Area map (2D / 3D)
- Area map (rail) → polygon / rectangle tool (top right), or import KML / KMZ.
- ⌂ Place takeoff at the real launch spot (height reference).
- Pick a preset, or set Camera → Flight height → Overlap → Pattern.
- 2D ortho: Grid, gimbal −90°, overlap 75 / 65 %+. 3D: Oblique 5 or Cross, gimbal −50…−65°, 80 / 70 %+.
- Capture: Distance (fast) or Stop & shoot (sharp). Speed Auto.
- Hilly site: Terrain following ON (needs ⌂).
- Check cards (time, batteries, GSD, max above home) and warnings. Optional: Side-look, Detail zones, Wind.
- Export ZIP or Upload to RC → Fly tutorial.
Orbit (object 3D)
- Switch mode to Orbit. ⌖ Place POI at the object centre.
- Set object height + diameter. Distance / rings: Auto or manual.
- Optional: Nadir top cap for roofs; direction, start bearing.
- ⌂ Takeoff marker for ring start; Terrain ON if ground differs from home.
- Check ring heights (above home) vs. max height.
- Export / Upload. Mission stops & shoots at each waypoint.
Facade (wall)
- Switch mode to Facade. Draw a line along the wall base (line tool, top right).
- Pick flight side (left / right of line) and distance to wall.
- Set lowest / highest row (above home). Gimbal 0° = perpendicular.
- Overlap 80 / 70 %+. Mind obstacle sensing near the wall.
- Export / Upload. Stop & shoot per waypoint.
Video shot (dolly)
- Mode Video. Pan the map to the subject.
- Fastest start: Video → Shot recipes → pick (Push-in, Pull-out, Truck, Crane, Orbit arc, Fly-over) → direction + distance → + Insert. Then tune.
- Manual: ⌂ takeoff at the launch spot → + Add waypoint → tap the track → ✓ Done. Drag pins.
- Per point: height above home, speed (0 = cruise), hold (use 2 s at both ends as edit handles).
- Look per point: POI (lock on subject), fixed heading (truck / crane), path (flight direction). Gimbal: angle / aim at POI / level.
- Path & smoothing: roundness 0.8–0.9, ease 0.8+, low accel limits = floaty dolly; raise for energetic.
- Shot preview: scrub; check speed, yaw rate, pitch. No spikes, no warnings.
- Video camera: fps 24 / 25 / 30, 180° shutter, ND to match. Set the same in DJI Fly.
- Export / Upload, take off at home, start in DJI Fly. First run at reduced speed.
Shot design (dolly basics)
- Dolly ≠ flying the camera. Path decides where the drone goes, Look decides where the camera points. Dolly feel = translate smoothly while the view stays locked (POI or fixed heading), not “along path”.
- Subject lock (POI): push-in, pull-out, arc. Fixed heading: truck, crane (parallax, straight verticals). Along path: fly-over, tracking.
- Speed: apparent motion = speed ÷ distance to subject. Close (10–20 m): 1.5–3 m/s. Mid (30–60 m): 3–6 m/s. Far / landscape: 8–12 m/s.
- Smoothness: few points, long gentle legs. Ease in/out ≥ 0.8, roundness 0.8–0.9. Yaw ≤ 10–15 °/s, gimbal ≤ 5–8 °/s for slow moves.
- Keep 2 s holds at start and end (edit handles). Start and end on a stable frame.
- Height: all heights above home point. Lower = more parallax and speed feel; higher = map-like. Check clearance on the preview and with Terrain ON.
- Camera: 24 / 25 fps + 180° shutter (1/48–1/50) for cinematic blur, ND as advised. 5.1K / 4K H.265; fix white balance.
- Autofocus: Shot preview shows focus distance + sharp zone per moment (POI in frame → POI; else ground point under the view centre; else ∞). Short lens / 4K: hyperfocal ≈ 6 m → MF at the shown distance, no hunting. Big focus range + subject close → AF-C on the subject.
- Check in 3D: map tilt (3-finger drag, right-drag, ⛰, Layers slider) shows the elevated path; 3D view shows frustum, focus plane, sharp zone and the camera view (📷).
- Safety: VLOS, obstacles along the whole spline, wind < 8 m/s for slow moves, fly a test at 50 % speed first.
- Recipes: Video → Shot recipes inserts any of these as editable waypoints around the map centre.
Detail zones + re-fly gaps
- Grid mode with a survey polygon.
- Detail zones: 🏢 Find (OSM buildings / trees) or + Draw zone → tap corners → Finish.
- Tune per zone: overlap, pattern, altitude ×, gimbal. Zones only = patch mission.
- After the flight: Gap check → select JPGs → Analyze.
- Red = under-covered. Create re-fly mission → export. Back to full plan to revert.
Upload & fly
- Create one saved dummy waypoint mission (2 pts) per battery in DJI Fly.
- Remote controller: USB-C → Detect RC (ADB or MTP; RC Pro on Termux: direct).
- Assign mission → slot → Upload. Backups in
rc_backups/. - FLY (rail): pre-flight checklist, Prepare Mn (opens it in DJI Fly via macro), check screenshot, Hold to START.
- Macros: Record once (Open Mn, Start, Pause, Resume), test, save.
- VLOS. RC pause / RTH always overrides. Swap battery → next mission.
- Optional: Live tab follows the flight log on the map (API key).
Process & measure
- Copy photos (SD) to a folder. Start NodeODM (Automatic processing → Docker).
- Folder → quality → Upload & process. Result in
odm_*. - Results: folder → Scan → Orthophoto / Heights overlay.
- Measure: distance / area. Volume: Outline a pile, choose base → Finish.
- Change: Set A (old), Set B (new) → Compare A → B.
- Needs numpy, tifffile, pillow on the PC.
Side-look shots
- Grid mode, terrain following for slopes.
- Side-look shots ON: sides, side pitch, every N points.
- Slope ON: side pitch follows terrain normal.
- Capture Stop or Distance (hybrid). Expect longer flight time.
- Test a short run in DJI Fly first.
Quick answers
Is Mavic Mapper really free?
Yes. JK4U Mavic Mapper is free of charge and without restrictions: no trial timer, no licence key, no subscription, no account and no locked features.
Does the Mavic 3 Pro waypoint planner work offline?
Yes. Planning runs entirely on your computer. Only optional lookups – map tiles, terrain elevation (DEM), OpenStreetMap zones, place search and weather – use the internet.
Which DJI drones does it support?
This is the Mavic 3 Pro edition with all three cameras: Hasselblad 24 mm, medium tele 70 mm and tele 166 mm. Other DJI aircraft that accept DJI WPML waypoint missions in DJI Fly (for example the Mavic 3 family, Air 3 and Mini 4 Pro) use the same file format; the planner has an adjustable drone-model code, but only the Mavic 3 Pro is tested – always try a short mission first.
How do I get a waypoint mission into DJI Fly?
Two ways: let Mavic Mapper upload it over USB-C with ADB (one click per battery, with automatic backup), or follow the manual guide: create a placeholder waypoint mission in DJI Fly, then replace its KMZ file in Android/data/dji.go.v5/files/waypoint with your own, renamed to the same file name.
How does the USB / ADB upload to the DJI RC Pro work?
Mavic Mapper installs Google's ADB platform-tools automatically, detects your controller over USB-C, lists the mission slots created by your placeholder missions and pushes each KMZ into its slot. It backs up the replaced mission, copies the drone ID codes, verifies the file size and restarts DJI Fly.
Do I need to know ADB?
No. ADB (Android Debug Bridge) is only the transport. Mavic Mapper downloads it for you; you just enable USB debugging on the controller once and accept the prompt.
Which controllers can I upload to?
DJI RC Pro, DJI RC 2 and Android phones running DJI Fly via ADB, plus Windows file transfer (MTP) as a fallback and an on-RC mode where the planner runs on the controller itself.
Is overwriting a mission on my controller safe?
The original mission file is backed up to a local rc_backups folder before every upload and can be restored with one button. Only the placeholder missions you assign are touched.
Are all flight heights above the home point?
Yes. DJI waypoint missions use heights relative to the takeoff point, and Mavic Mapper does the same. Place the home marker where you actually launch; the planner warns when the highest waypoint exceeds your height limit (default 120 m) measured from the home point.
Are the camera settings saved in the mission?
No. Waypoint files cannot carry exposure. The planner calculates shutter, ISO, aperture, ND filter, white balance and focus for you to set in DJI Fly, and writes them to summary.txt.
What overlap and altitude should I use for Mavic 3 Pro photogrammetry?
For 2D orthomosaics use about 75/65 % front/side overlap with the gimbal at −90°; for 3D models use 80/70 % or more with an oblique pattern and −50° to −65° gimbal. At 80 m the Hasselblad camera gives roughly 2.1 cm/px; the Mission Lab on this page calculates GSD, photos and flight time for any setting.
Can it plan 3D models, orbits and façade scans?
Yes: crosshatch and oblique 4/5 grids, multi-ring POI orbits with a nadir top cap, and façade scans with perpendicular rows – each with live photo count, GSD, flight time and battery estimates.
Does it support terrain following?
Yes. Waypoint heights can be corrected with real elevation data (SRTM, EU-DEM, ASTER or Mapzen) so ground clearance and GSD stay constant over hills. DEMs ignore buildings and trees, so always check obstacles.
Can it plan cinematic video missions?
Yes. Six shot recipes (push-in, pull-out, truck, crane, arc, tracking) built on smooth spline paths with point-of-interest or fixed look modes, yaw and gimbal limits, easing and automatic exposure advice for 5.1K/4K video.
Can I process the photos in WebODM or OpenDroneMap?
Yes. Each export includes webodm_options.json tuned to the mission with fast, balanced and high quality presets.
How many batteries will my mission need?
The planner splits missions by battery budget (22 minutes default), balances the flights and writes one KMZ per battery; a resume function restarts from any waypoint after an interruption.
Is it safe to fly the plans blindly?
No. Always fly within visual line of sight, respect geo-zones and local rules, check every path for obstacles (trees, wires, cranes), set RTH height in DJI Fly and test each new setup on a small, open area first. The RC pause / RTH always overrides a mission.
 100% FREE · NO RESTRICTIONS
Ready for take-off?
Download Mavic Mapper and plan your first mission in minutes.
⬇ Download JK4U-Mavic-Mapper.exeDownload the single .exe – no installer, no wizard.
Double-click it. The planner opens in your browser.
Draw, calculate, export the KMZ and fly.
Windows may show a SmartScreen notice for unsigned programs – choose “More info → Run anyway” if you trust the source. Always test new missions slowly, keep the aircraft within visual line of sight and follow your local drone regulations.